Watch the video
Paper-related demonstration: continuum-robot motion and experiments. · Yang et al. · 480p source video
01 / STUDY
Mechanism and experiments
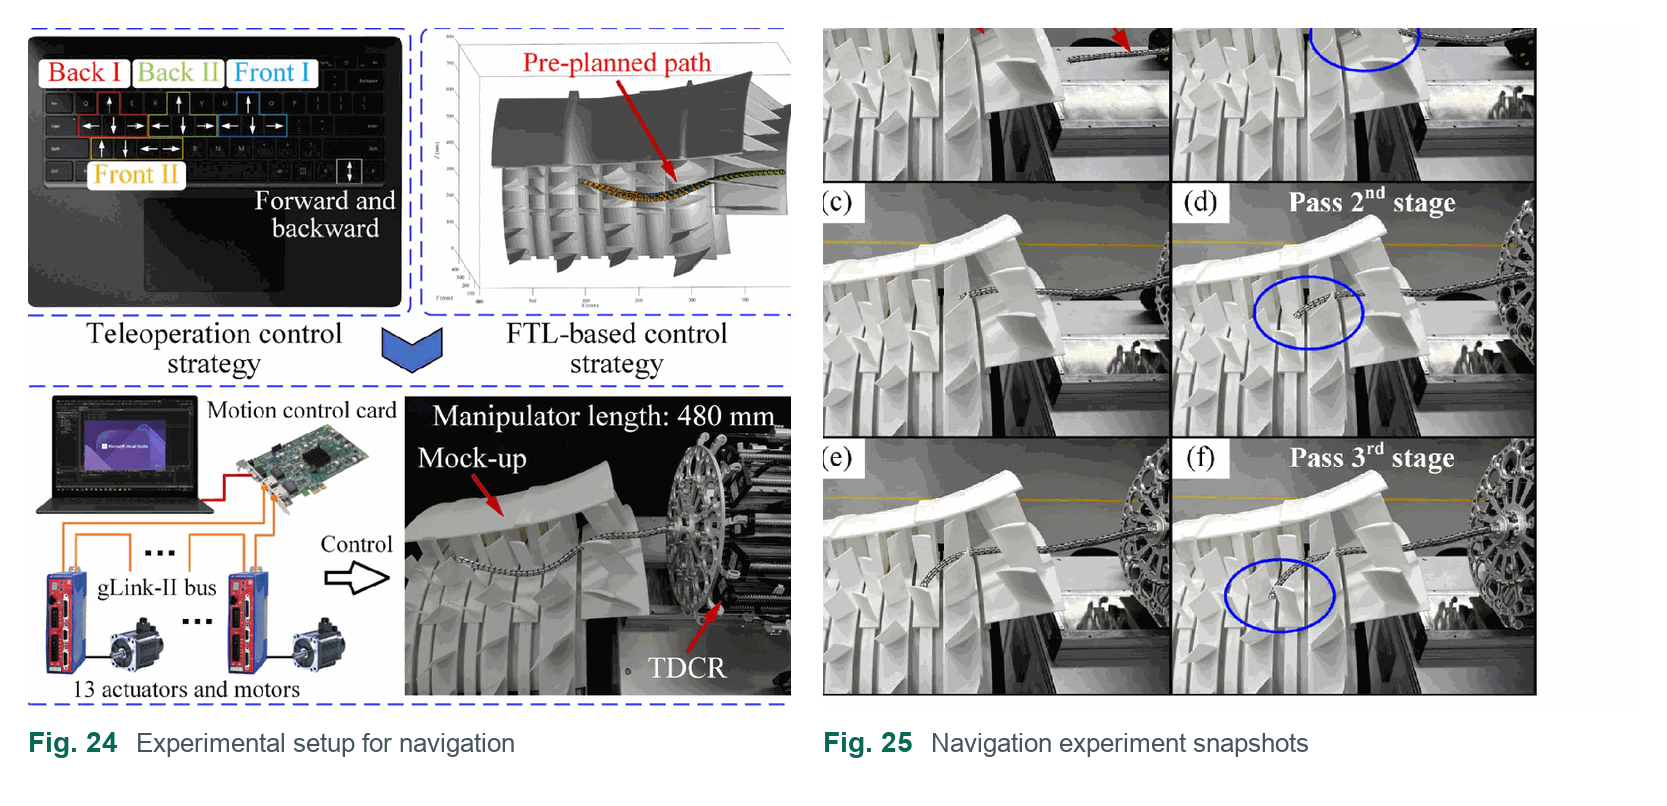
The research models friction and joint constraints, and validates shape estimation and navigation. The figure shows navigation through an aero-engine blade mock-up. “Contact-aided” describes contact within the compliant mechanism.
02 / CONTEXT
Test conditions and scope
Blade-model experiments validated navigation and shape estimation. Loads, precision and reliability with maintenance tools need further testing.
03 / SOURCE